 正版
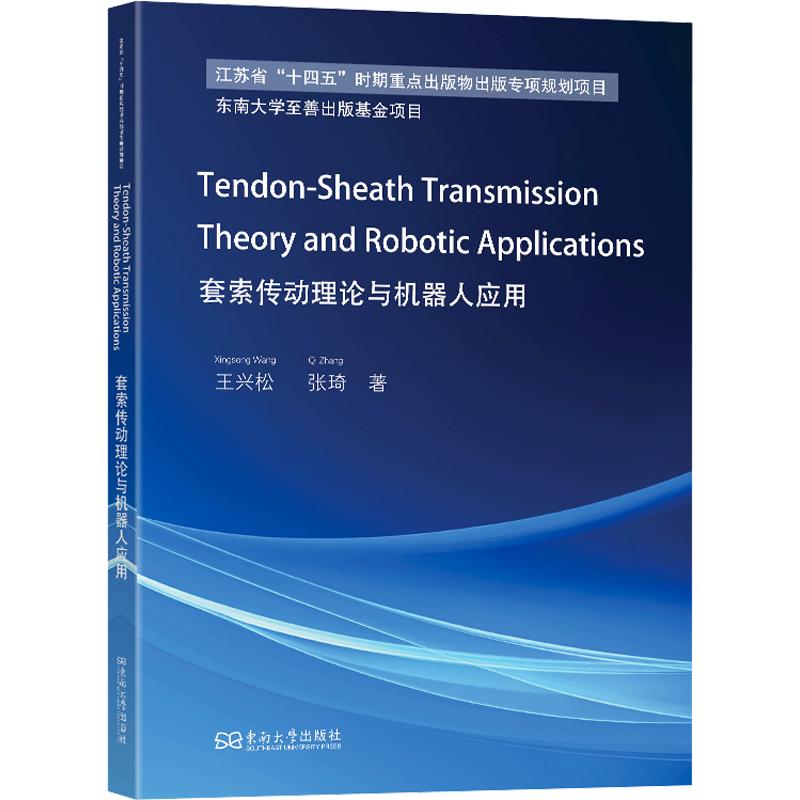
套索传动理论与机器人应用
- 书名
- 套索传动理论与机器人应用
- 作者
- 王兴松,张琦 著
- 出版社
- 东南大学出版社
- 出版时间
- 2025-12-01
- ISBN
- 9787576622829
- 货号
- 1204326438
- 品相
- 全新
- 分类
- 当代·工业
- 书名
- 套索传动理论与机器人应用
- 作者
- 王兴松,张琦 著
- 出版社
- 东南大学出版社
- 出版时间
- 2025-12-01
- ISBN
- 9787576622829
- 货号
- 1204326438
- 品相
- 全新
- 分类
- 当代·工业
目录▼
Chapter 1 Introduction
1.1 Introduction
1.2 Light and slender robots
1.3 Tendon-sheath transmission
1.4 Bio-aspects of tendon-sheath transmission
References
Chapter 2 Tendon-Sheath Transmission System
2.1 Single tendon-sheath transmission system
2.2 Double tendon-sheath transmission system
2.3 Multi-tendon-sheath transmission system
References
Chapter 3 Transmission Characteristics of Tendon-Sheath System
3.1 Transmission characteristics of single tendon-sheath mechanism
3.2 Transmission characteristics of double tendon-sheath mechanism
3.3 Influencing factors of transmission characteristics
3.4 Comprehensive optimization of transmission distance and space angle
References
Chapter 4 Transmission Model of Tendon-Sheath System
4.1 Transmission model of single tendon-sheath system
4.2 Transmission model of double tendon-sheath system
4.3 Dynamic model of tendon-sheath system
References
Chapter 5 Control of Tendon-Sheath Transmission Mechanism
5.1 Inverse model compensation with PID control
5.2 Model-based sliding mode control
5.3 Neural network-based sliding mode control
References
Chapter 6 Mechanism of Tendon-Sheath Transmitted Slender Robots
6.1 Macro and micro configurations of slender robots
6.2 Morphological characteristics of tendon-sheath transmitted slender continuum robots
6.3 Mechanism of tendon-sheath transmitted macro slender link series
6.4 Kinematics analysis of micro tip manipulators
6.5 Compliant design of micro tip operators
References
Chapter 7 Geometry Estimation of Tendon-Sheath Transmitted Slender Robots
7.1 Body shape reconstruction from joint angles of series link
7.2 Body shape reconstruction from near-end sensing
7.3 Body shape reconstruction from distal-end sensing
7.4 Geometry shape sensing of sheath configuration
7.5 Fibre bragg grating for sensing continuum body shape
7.6 Force and displacement sensing of micro tip manipulation using FBG sensors
References
Chapter 8 Tendon-Sheath Transmitted Slender Robots for Detection and Rescue
8.1 System consideration of detection and rescue robots
8.2 Design of the search and rescue robots
8.3 Detection system with inspection experiments
8.4 Monocular vision positioning systems
References
Chapter 9 Tendon-Sheath Transmitted NOTES Robots
9.1 State of the art on natural orifice translumenal endoscopic surgery robots
9.2 Mechanical consideration on tendon-sheath transmission for NOTES robots
9.3 A tendon-sheath-based dilatation device for hysteroscopy
9.4 Tendon-sheath transmitted scale to scale mapping remote operation manipulator
References
Chapter 10 Tendon-Sheath Transmitted Soft Light Exoskeletons
10.1 State of the art on lightweight exoskeleton
10.2 Tendon-sheath transmitted lower limb exoskeleton
10.3 Tendon-sheath transmitted upper limb exoskeleton
10.4 Tendon-sheath transmitted passive light exoskeleton
References
Chapter 11 Current Issues & Future Perspective
11.1 Current issues
11.2 Future perspective
Index
文摘▼
本书详细介绍作者课题组为将套索传动技术运用于细长机器人所开展的其传动与控制理论创新成果,主要包括了套索传动装置的结构设计、套索传动力和位移传递特性建模、套索传动机构的精密运动控制理论与误差补偿方法、基于宏-微机器人理论的套索传动细长机器人结构体设计与建模、细长结构体形态测量与重构理论、细长机器人微型末端执行器设计与精密运动控制等基础理论。