 正版
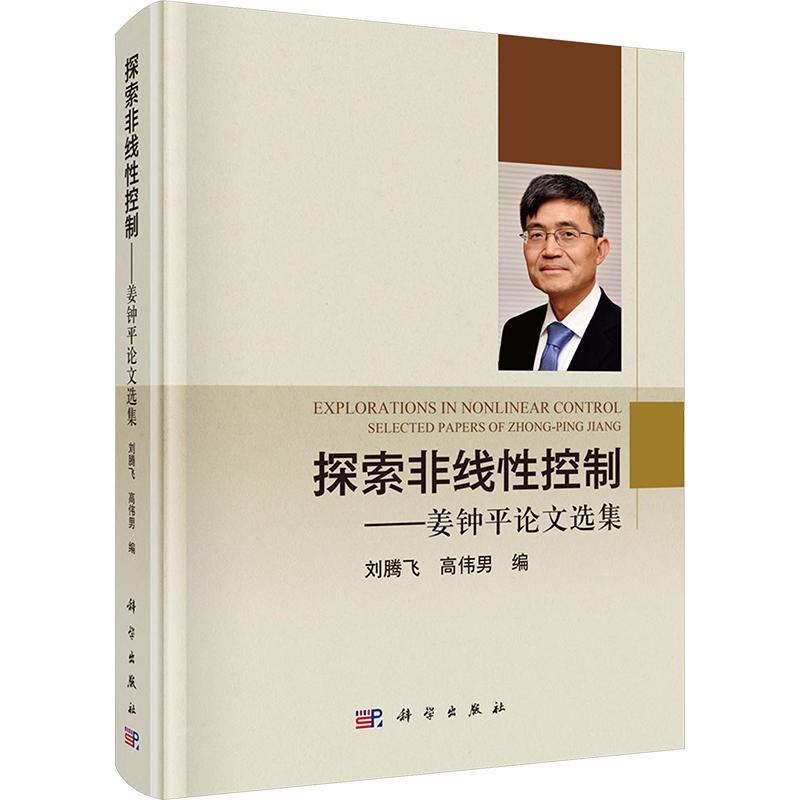
探索非线性控制——姜钟平论文选集
- 书名
- 探索非线性控制——姜钟平论文选集
- 作者
- 刘腾飞,高伟男 编
- 出版社
- 科学出版社
- 出版时间
- 2026-09-01
- ISBN
- 9787030857095
- 货号
- 1204561929
- 品相
- 全新
- 分类
- 当代·工业
- 书名
- 探索非线性控制——姜钟平论文选集
- 作者
- 刘腾飞,高伟男 编
- 出版社
- 科学出版社
- 出版时间
- 2026-09-01
- ISBN
- 9787030857095
- 货号
- 1204561929
- 品相
- 全新
- 分类
- 当代·工业
目录▼
序
Preface
Small-Gain Theorem for ISS Systems and Applications 1
A Lyapunov Formulation of the Nonlinear Small-Gain Theorem for Interconnected ISS Systems 29
A Small-Gain Control Method for Nonlinear Cascaded Systems with Dynamic Uncertainties 42
Tracking Control of Mobile Robots: A Case Study in Backstepping 83
Design of Robust Adaptive Controllers for Nonlinear Systems with Dynamic Uncertainties 102
Input-to-State Stability for Discrete-Time Nonlinear Systems 134
Global Tracking Control of Underactuated Ships by Lyapunovs Direct Method 159
On the Liapunov-Krasovskii Methodology for the ISS of Systems Described by Coupled Delay Differential and Difference Equations 175
Finite-Time Input-to-State Stability and Applications to Finite-Time Control Design 196
Computational Adaptive Optimal Control for Continuous-Time Linear Systems with Completely Unknown Dynamics 226
A Small-Gain Approach to Robust Event-Triggered Control of Nonlinear Systems 240
Adaptive Dynamic Programming and Adaptive Optimal Output Regulation of Linear Systems 271
Value Iteration and Adaptive Dynamic Programming for Data-Driven Adaptive Optimal Control Design 287
Robust Policy Iteration for Continuous-Time Linear Quadratic Regulation 319
Small-Disturbance Input-to-State Stability of Perturbed Gradient Flows: Applications to LQR Problem 341
后记 369
Postscript 371
文摘▼
本书总结了姜钟平教授30余年在非线性系统控制、稳定性理论与智能控制等领域的学术工作。主要收录了姜钟平教授及其合作者的代表性研究论文,内容涵盖非线性小增益定理、输入到状态稳定性理论、反步法跟踪控制、鲁棒自适应控制、事件触发控制、数据驱动控制、李雅普诺夫-克拉索夫斯基(Lyapunov-Krasovskii)泛函方法,以及梯度流鲁棒性分析等前沿方向,并涵盖了上述理论在欠驱动机械系统、移动机器人、电力系统等工程领域中的应用。全书兼具理论与应用价值,可为复杂动态系统分析与控制器设计提供参考。
本书适合从事控制理论与控制工程、系统科学、人工智能、应用数学等相关领域的科研人员、高校教师和研究生参考使用。